Xincheng He 何欣成
I am an undergraduate student studying Mathematics at Zhiyuan College, Shanghai Jiao Tong University, and I expect to graduate in June 2027.
I began my research at Shanghai Jiao Tong University under the supervision of Prof. Wenqiang Xu and Prof. Cewu Lu, focusing on physical simulation, computer graphics, and robot learning. Currently, I work with Prof. Chenfanfu Jiang and Prof. Yin Yang at the University of California, Los Angeles (UCLA) on Skill2Real, an agentic sim-to-real framework.
CV|Github|Google Scholar|ORCID|Email: xinchenghe@sjtu.edu.cn
Research
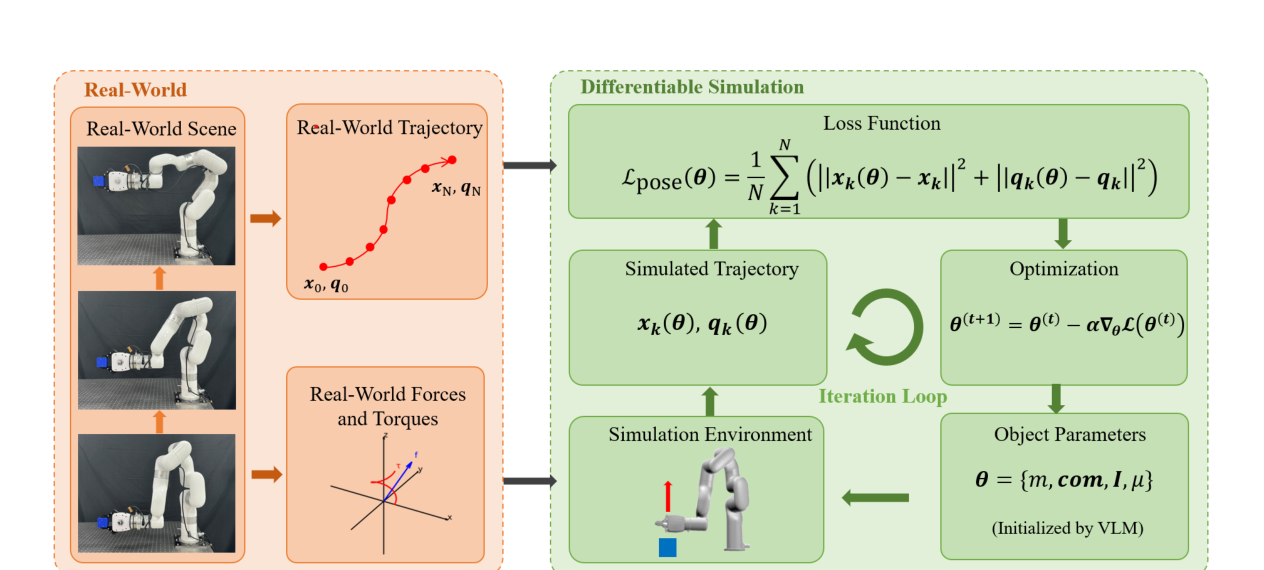
My research focuses on building physical intelligence by combining scalable simulation, differentiable physics, and agentic robot learning. In my current Skill2Real project, I develop agent-callable robot interfaces and critic-guided hierarchical skill learning for zero-shot sim-to-real deployment. I am particularly interested in systems that use physical priors and real-world feedback to learn reusable manipulation skills.
* Equal contribution.
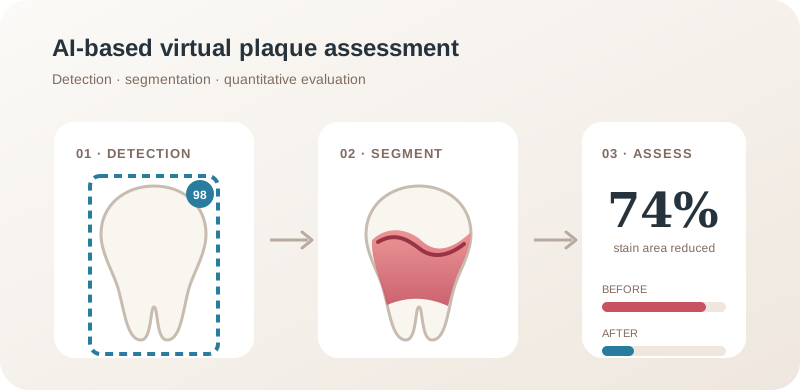
Evaluation of Toothbrush Quality Using AI-based Virtual Tooth Plaque Assessment
International Conference on Control, Automation and Diagnosis (ICCAD), 2025
Experience
University of California, Los Angeles
2025.05 - 2025.08; 2026.03 - PresentUndergraduate Researcher at the Artificial Intelligence & Visual Computing Laboratory
Advisors: Prof. Chenfanfu Jiang, Prof. Yin Yang
Shanghai Jiao Tong University
2023.09 - PresentUndergraduate Student at Zhiyuan College
Research Advisors: Prof. Wenqiang Xu, Prof. Cewu Lu